
Wheel-legged self-balancing robot
A hybrid wheel-leg balancing robot built on an STM32 controller. It balances on two wheels for fast driving and uses servo-driven legs to lift one or both sides over obstacles. A 2.4 GHz handheld remote handles driving, speed switching and leg lifting.
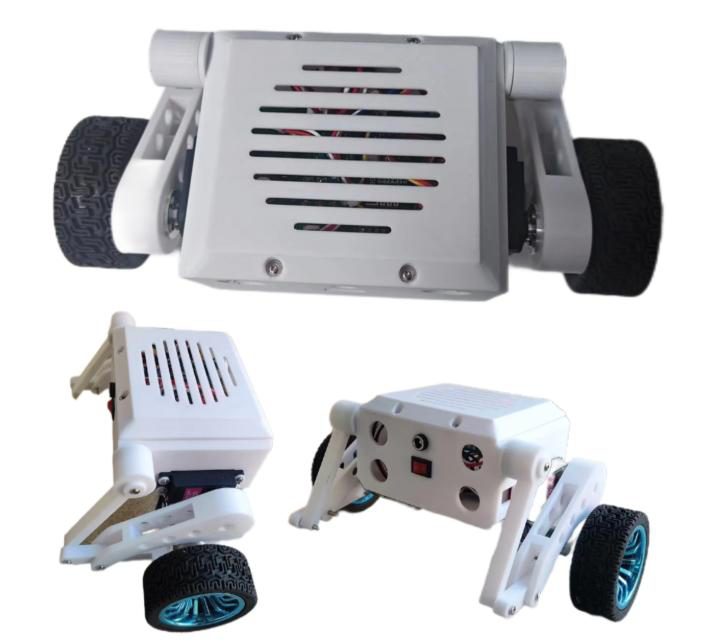
Tech stack
- Main controller
- STM32F4 series MCU
- Sensors
- MPU-6050 IMU for attitude sensing
- Drive
- Dual DC gear motors, differential steering
- Legs
- Four 35 kg·cm digital servos for leg lift and tilt, synchronous 50 Hz PWM
- Balance control
- Complementary or Kalman filter sensor fusion, PID or LQR balancing, safe landing / alarm on imbalance
- Wireless
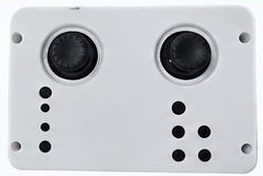
- 2.4 GHz dual-joystick remote controller
- Power
- 3S 11.1 V lithium battery with low-voltage protection
- Expansion
- UART / I2C / PWM interfaces
What we built
- Mechanical integration and structural design
- Control board and power design
- Embedded firmware and motion control
- Wheel/leg mode switching and remote-control functions
- Debugging, testing and bring-up
Development time
20 days
Photos and design files
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730