
Offline voice-controlled quadruped
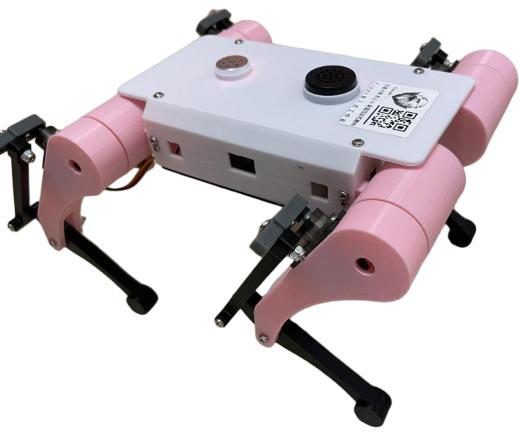
A compact four-legged robot with offline voice recognition and a 2.4 GHz remote, designed for education, prototyping and interactive displays. It responds to a wake word and fixed voice commands and can walk, turn, sit and stand. The team did the mechanical design, a custom control board and the firmware.
Tech stack
- Main controller
- STM32 on a custom control board
- Voice
- Offline wake word and predefined voice commands
- Audio
- Microphone and speaker for voice feedback and status prompts
- Actuators
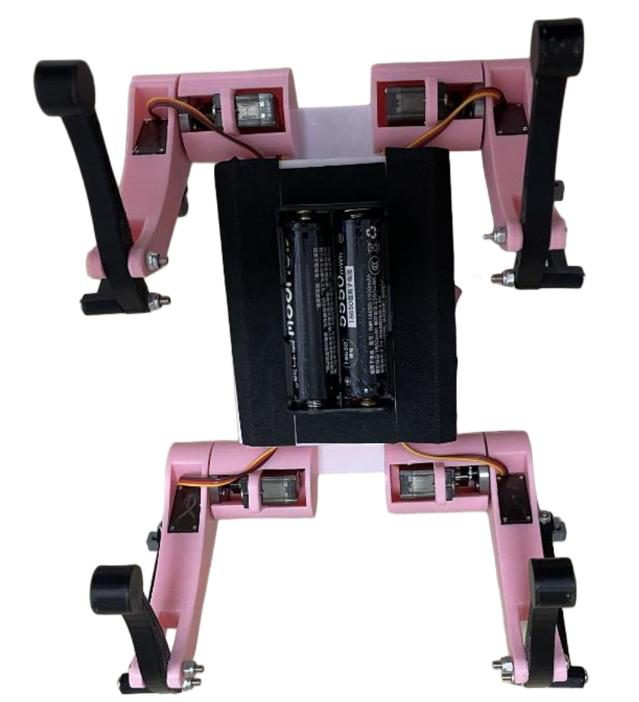
- 4 legs driven by multiple servos
- Wireless
- 2.4 GHz remote control
- Power
- 2S Li-ion battery (7.4 V) with voltage monitoring
- Structure
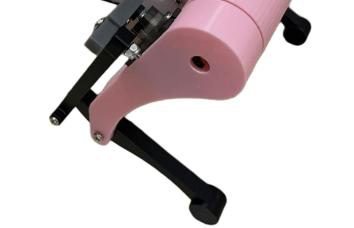
- 3D-printed body, four-leg linkage
What we built
- Mechanical design: compact 3D-printed structure, four-leg linkage, modular assembly
- Custom control board: servo interfaces, power management, microphone, speaker, buttons, battery monitoring
- Embedded software: servo and gait control, offline voice command recognition, 2.4 GHz remote receiver, predefined action library
- System integration and debugging
Development time
20 days
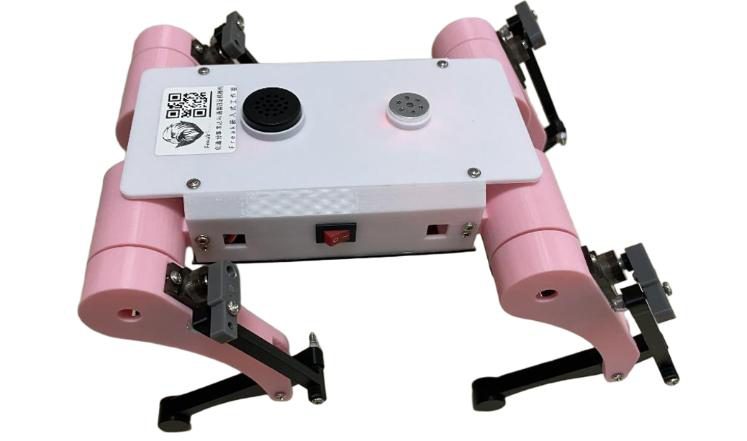
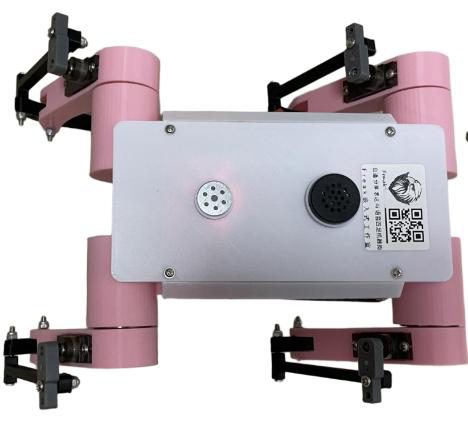
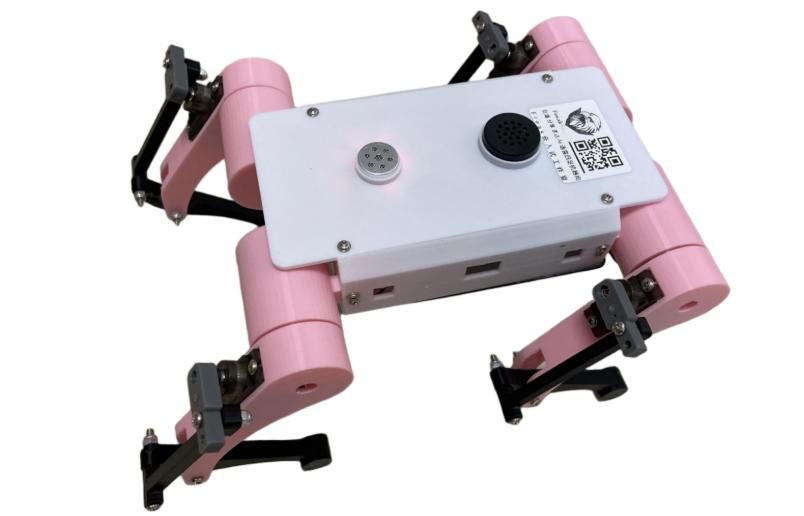
Photos and design files
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730