
ROS2 Omnidirectional Robot
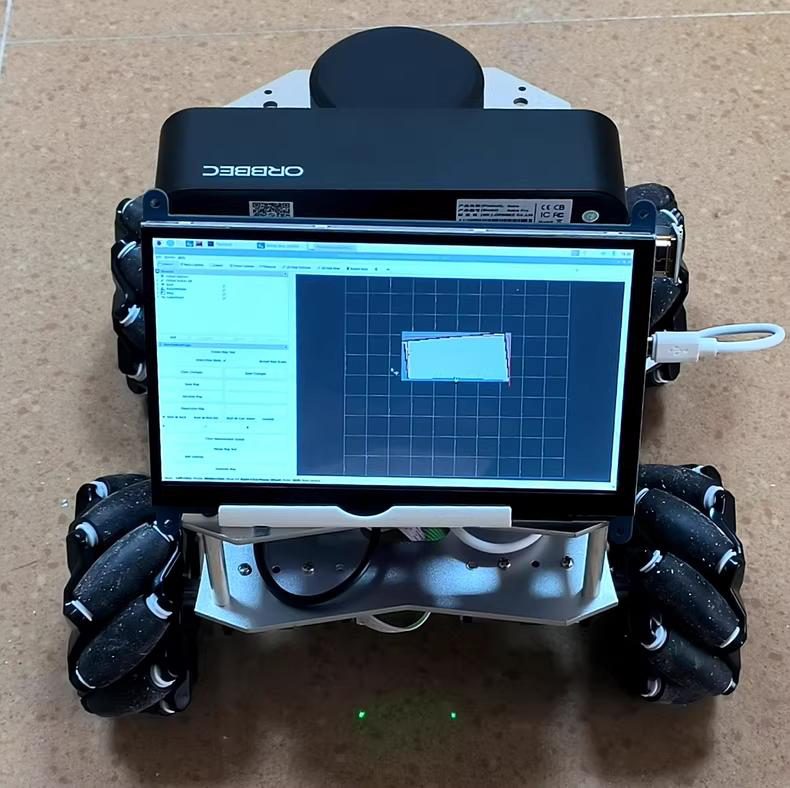
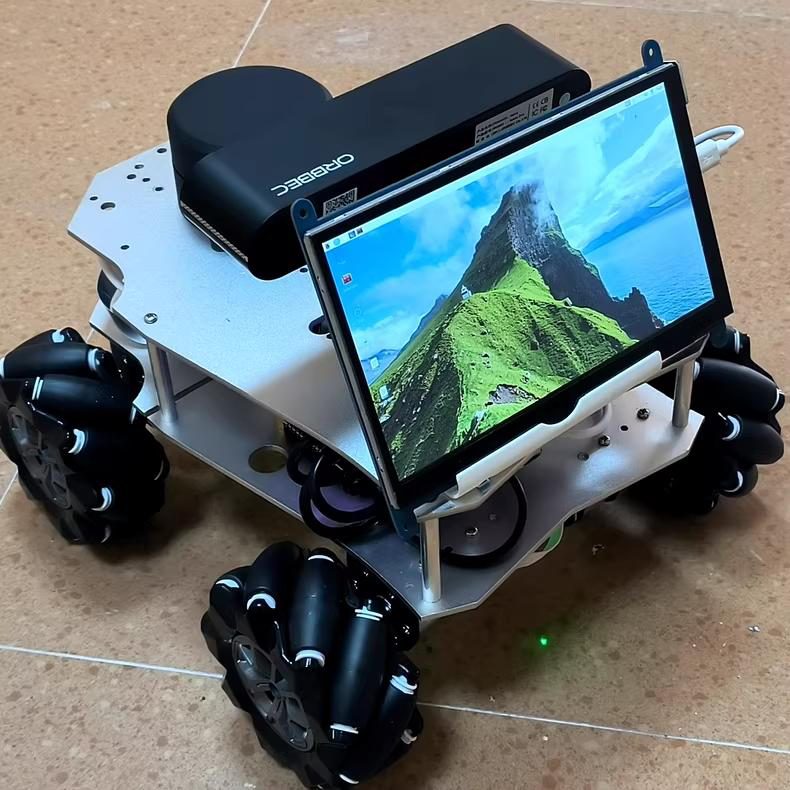
An omnidirectional mobile robot running ROS2, with LiDAR, a depth camera and room for expansion. It does SLAM mapping, autonomous navigation, obstacle avoidance and visual tracking. It is built for robotics teaching, research and real-world uses such as inspection and mapping.
Tech stack
- Main computer
- Raspberry Pi 4B, Ubuntu + ROS2
- Sensors
- EAI G4 LiDAR, Orbbec Astra Pro depth camera, IMU, wheel encoders
- Drive
- 4 independent mecanum wheels, motor drivers (PWM / serial)
- Mapping & navigation
- SLAM (Gmapping / Karto / Hector / Cartographer), TEB / DWA navigation, A* / RRT path planning
- Perception
- KCF visual tracking, line following
- Simulation
- Gazebo
- Power & frame
- 12 V battery, aluminum chassis
- Control
- Wi-Fi mobile app
What we built
- Robot chassis design
- Carrier board and hardware development: sensor integration, power management, motor control
- Embedded software on ROS2
- System integration, debugging and testing
- Delivered complete hardware, software source code, documentation, assembly drawings and a test guide
Development time
18 days
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730