
Large ROS Inspection Robot
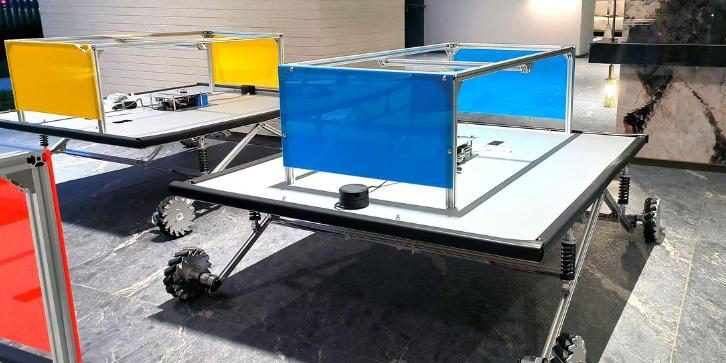
A ROS-based autonomous mobile inspection robot for campuses, factories, exhibition halls and other wide, flat indoor spaces. It builds a map with 360° lidar, plans its own patrol routes and avoids obstacles, and can also be driven remotely over 4G with live video. The open deck takes add-on payloads such as cameras, robotic arm modules or gas sensors.
Tech stack
- Software
- ROS navigation and mission execution; SLAM mapping, localization, path planning, obstacle avoidance
- Sensing
- 360° lidar
- Chassis
- Large omnidirectional mobile platform with independent spring suspension
- Link
- 4G remote control and live camera video
- Expansion
- Interfaces for cameras, robotic arm modules, gas sensors and other payloads; multi-robot coordination support
What we built
- Mechanical design and structural integration
- Control hardware and power system design
- Embedded device-side software
- Remote control terminal / monitoring interface
Development time
1 month
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730