
Small Dynamic Robot Dog
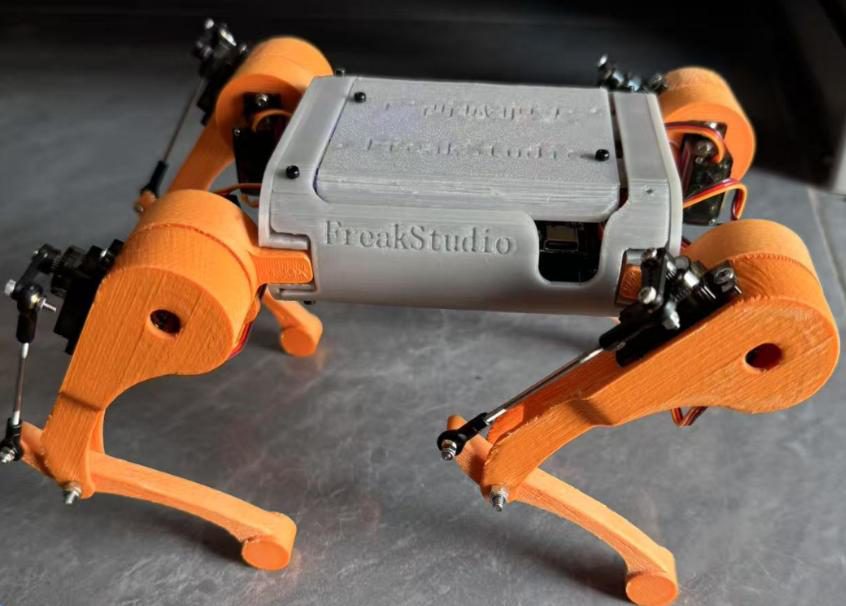
A compact quadruped robot with an 8-DOF leg structure for walking, balancing and teaching. Besides the mechanics, electronics and firmware, the team built a dedicated IDE for deploying, debugging and visual programming. The architecture is open for vision and AI add-ons.
Tech stack
- Legs
- 8-DOF servo leg structure with inverse kinematics
- Control
- Dynamic gait control and balance logic, IMU-fusion attitude stabilization
- Communication
- Web, serial and Wi-Fi
- Power
- Low-voltage monitoring and protection
- Supported controllers
- ESP32, STM32, Pyboard, K210
- Software
- Dedicated IDE: one-click configuration and upload, visual programming, parameter tuning and remote-control tools
- Expansion
- Open interfaces for vision and AI modules
What we built
- Mechanical design
- PCB / electronics design
- Device-side firmware
- Dedicated IDE / development tool design
- Motion control tuning and system integration
Development time
30 days
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730