
RM competition robot: omni-wheel chassis
An omni-wheel competition robot built to maneuver quickly in tight spaces. It also works as a base for teaching and further development. The team did the complete hardware, the chassis and gimbal mechanics, and the embedded software.
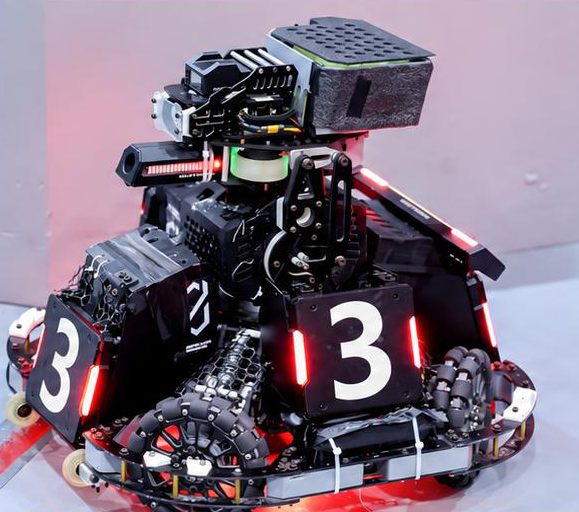
Tech stack
- Chassis
- Omni-wheel, omnidirectional mobility
- Motor control
- Multi-CAN motor control, CAN bus
- Compute
- Main controller with high-performance compute board
- Power
- Custom power distribution
- Firmware
- Kinematics, sensor fusion, RTOS-based task scheduling
- Mechanics
- Custom chassis and gimbal
What we built
- Complete hardware design: multi-CAN motor control, power distribution, main controller, external sensor interfaces, compute-board integration
- Mechanical design of chassis and gimbal
- Embedded software: CAN bus control, kinematics, sensor fusion, RTOS task scheduling
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730