
Underwater ROV, orange-shell build
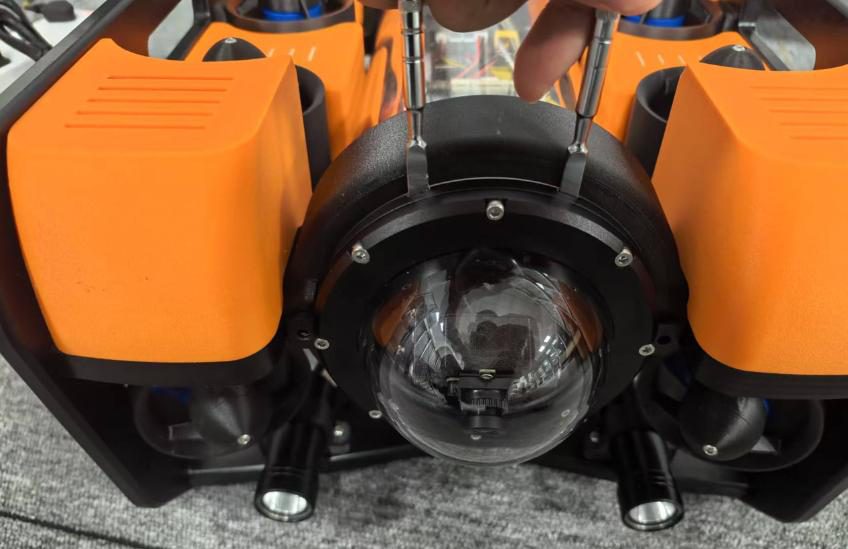
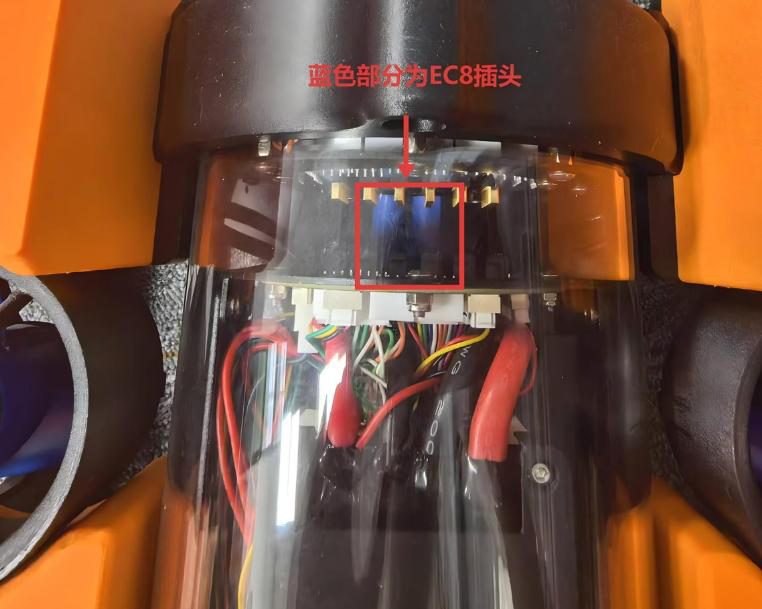
An underwater ROV build shown on the control-electronics slide of the Flat-Frame ROV case. The slide describes an RK3566 Linux main controller, a custom motion-control board driving the thrusters, an MS5837 depth sensor and a 1080p camera with live video, run from a Qt ground station on Windows or Linux. The photos show a vehicle with orange thruster shells, a front camera dome with two lights, and a clear electronics tube.
Tech stack
- Main controller
- RK3566 running Linux
- Motion control
- Custom motion-control board with PWM drive, current monitoring and protection
- Sensors
- MS5837 depth/pressure sensor
- Camera
- 1080p / 30 fps underwater camera with live video and recording
- Power
- Internal power system designed for up to 3 hours
- Software
- Manual and assisted cruise modes; UDP command and telemetry; Qt ground station for Windows and Linux; 4G remote control and video
What we built
- Mechanical design and assembly engineering
- Hardware and PCB design
- Embedded device-side software
- Remote-control terminal and UI
- Machining, integration and system bring-up
Development time
2 months
Photos and design files
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730