
Laser weeding robot
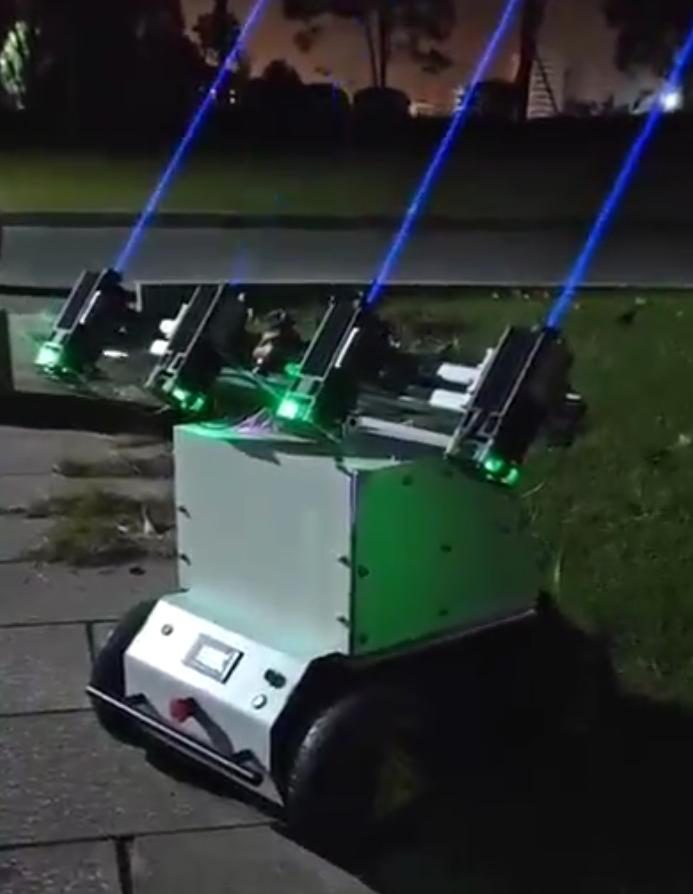
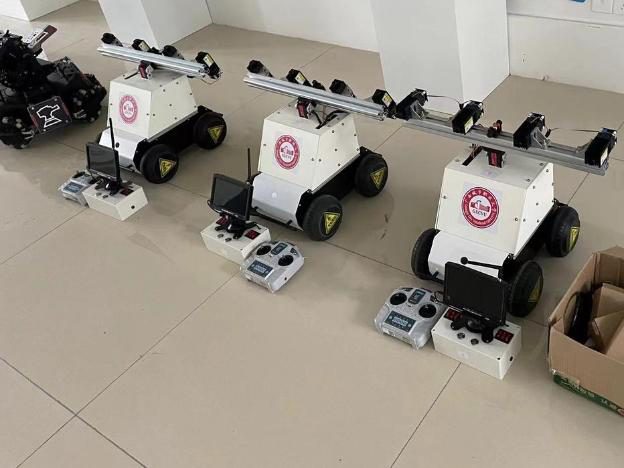
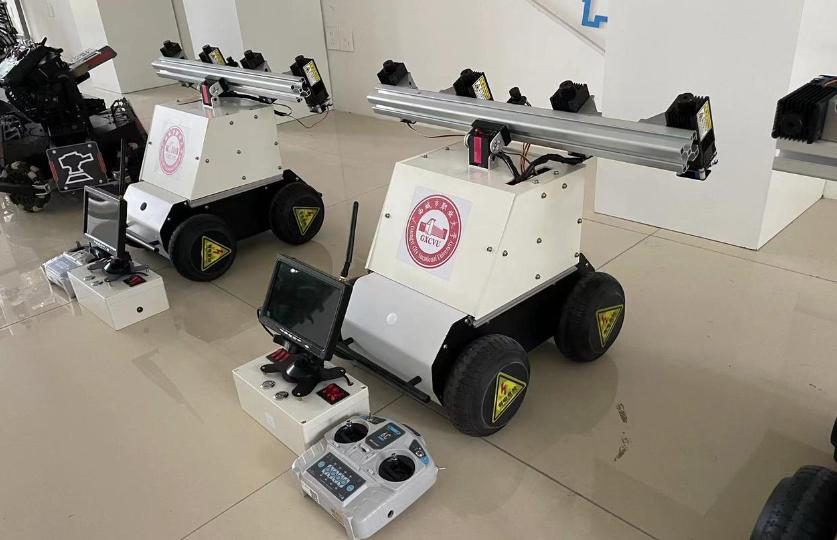
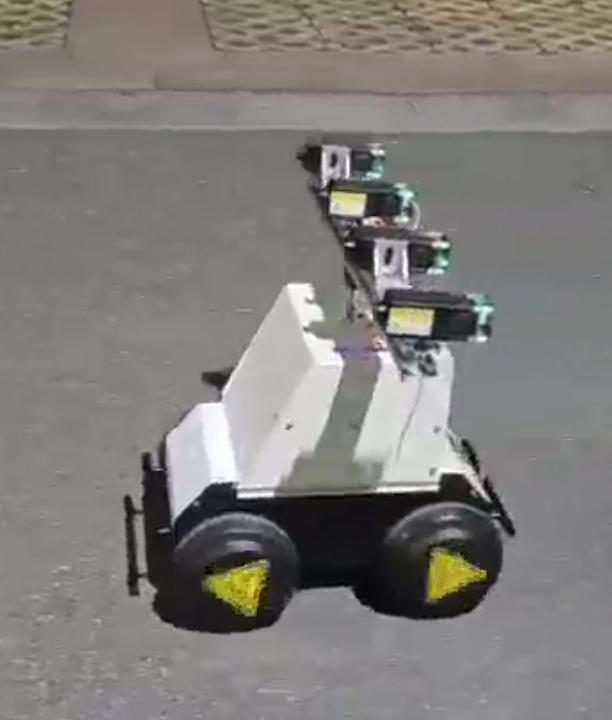
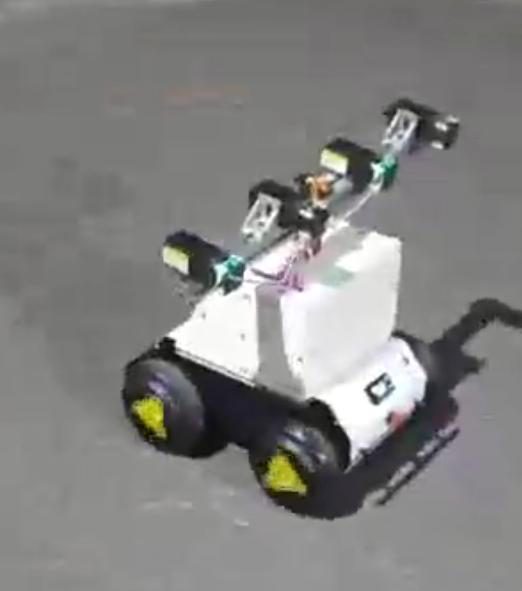
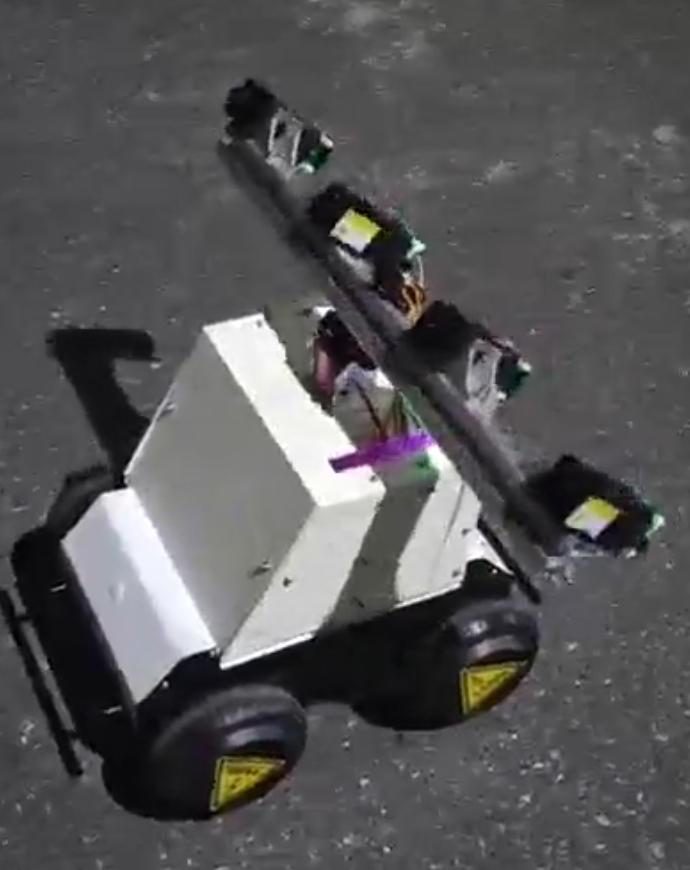
An agricultural service robot for row weeding and precision cutting with a high-power laser array. A four-wheel mobile base carries a laser beam that tilts on a single axis. An operator drives it remotely and aims through live video, and multi-channel safety interlocks guard the lasers. The system runs on ROS for mobility, control and teleoperation.
Tech stack
- Mobile base
- 4-wheel differential drive platform, fabricated body and protective enclosure
- Laser system
- High-power laser modules in groups, on a mounting beam with a single-axis pitch mechanism
- Controller
- Embedded controller with onboard control and safety logic; power distribution system
- Camera & link
- Camera with live 4G video transmission; wireless video link
- Software
- ROS-based mobility and teleoperation framework; chassis and pitch-axis control; laser enable, selection and firing logic
- Safety
- Multi-channel safety interlocks, dual-enable firing, fault handling and logging
- Operator station
- Remote control station for teleoperation and monitoring
What we built
- Mechanical design, fabrication and assembly of the base, enclosure, laser beam and pitch mechanism
- Hardware integration and power architecture, including laser grouping/switching and safety interlock circuitry
- Embedded device-side software: motion, pitch-axis and laser firing logic, status monitoring and logging
- Remote control station and video link
- ROS-based system integration and teleoperation framework
Development time
1 month
Photos and design files
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730