
Indoor Delivery Robot
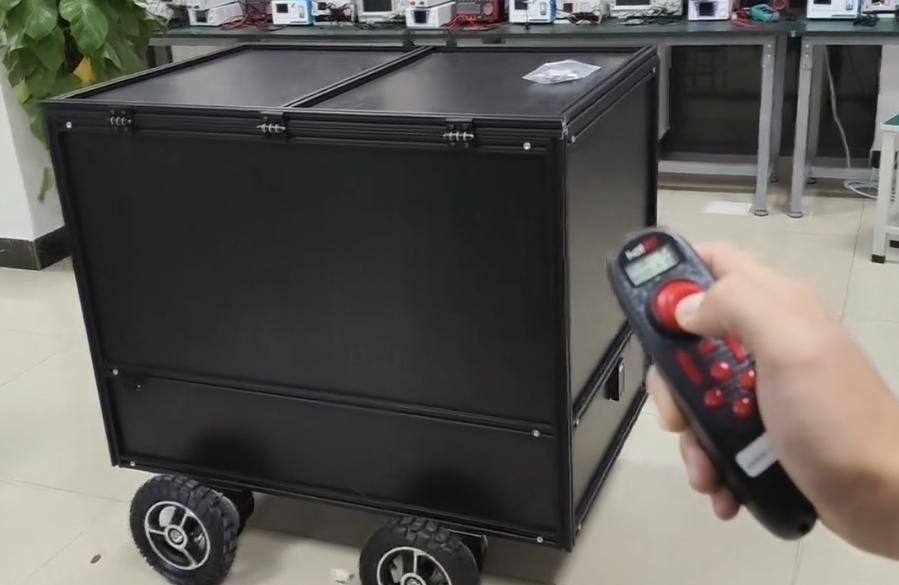
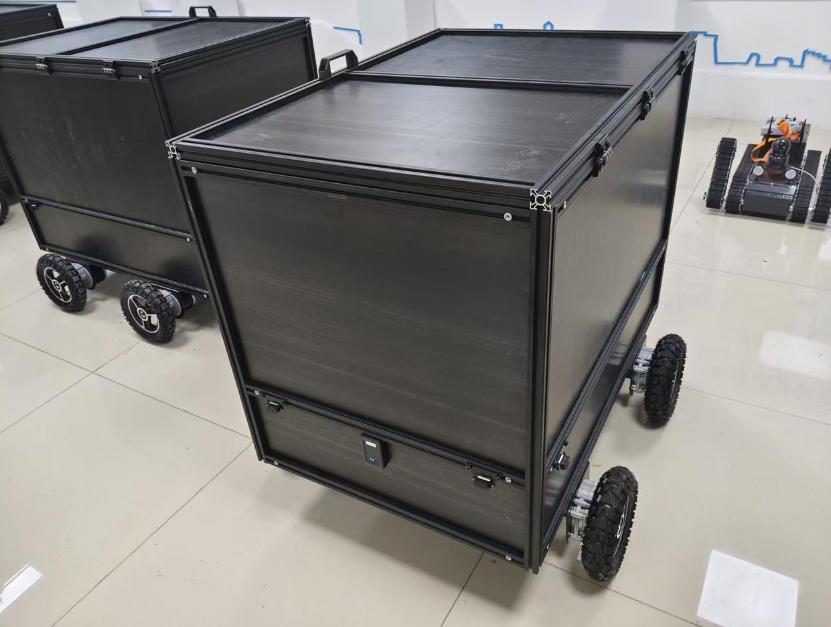
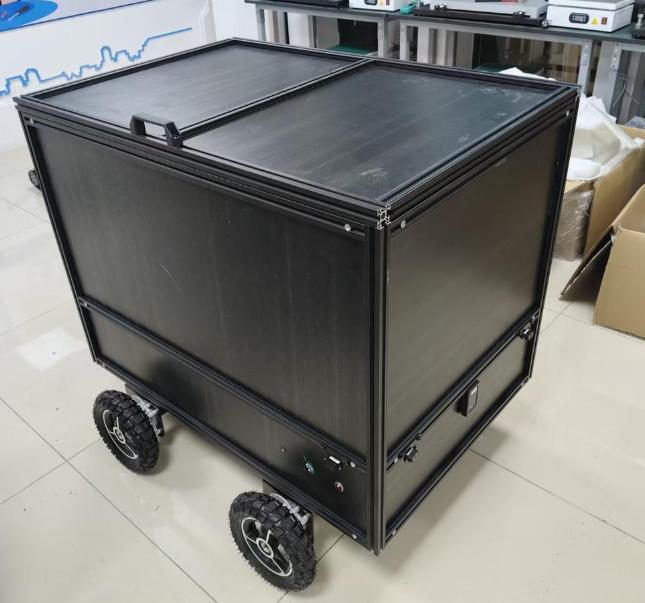
An indoor delivery robot for moving materials in factories, warehouses, labs and other indoor spaces. It follows a person wearing a UWB tag at a set distance, or can be driven with a handheld remote. Ultrasonic sensors stop it from running into obstacles, and it carries up to 200 kg in a lidded aluminium-frame box on four air-filled wheels.
Tech stack
- Main controller
- ESP32 running FreeRTOS
- Positioning
- UWB modules front and rear (UART); follow distance 1–7 m, adjustable
- Obstacle sensing
- 4 ultrasonic sensors (RS485) and 6-axis IMU, multi-sensor fusion
- Camera
- 1080p camera with video streaming and recording
- Drive
- 4WD differential drive, in-place turning, 10-inch air-filled tires, PID / S-curve motor control
- Power
- 24 V 20 Ah battery with BMS; ≈4 h charge; up to 15 km per charge
- Load & speed
- ≤200 kg payload, ≈30 kg empty, up to 5 km/h, ≤10° slope, 5 cm obstacles
- Remote
- Handheld remote, ≤40 m range; optional 4G remote monitoring
What we built
- Mechanical design: aluminium-frame body, lidded cargo box, 4WD chassis
- Control hardware: ESP32 main board, motor drivers, power and BMS, sensor wiring
- Embedded software: UWB follow algorithm, remote control, obstacle-avoidance logic, motor control
- Status display (voltage, distance, sensor data) and video streaming
Development time
1 month
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730