
Bionic Hexapod Robot
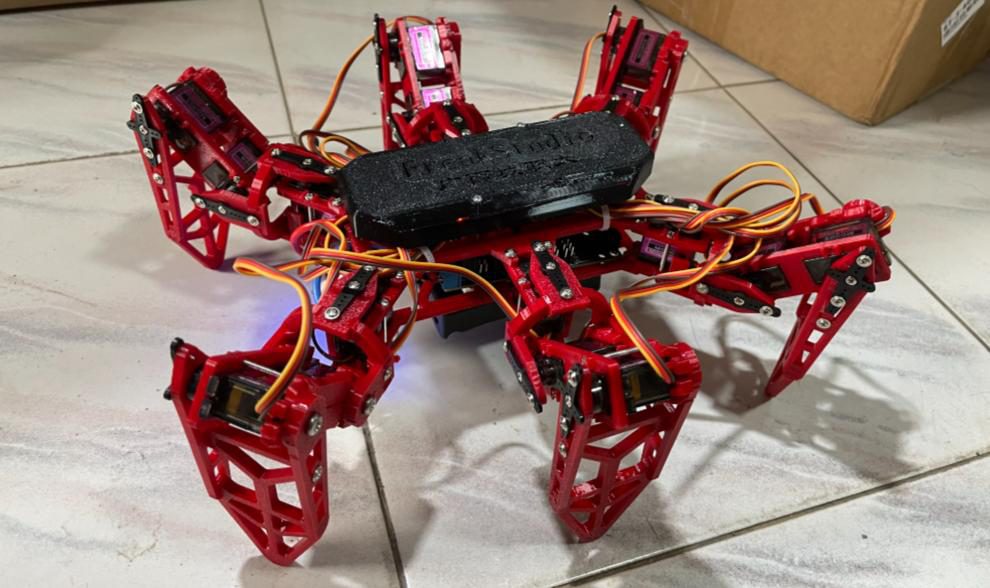
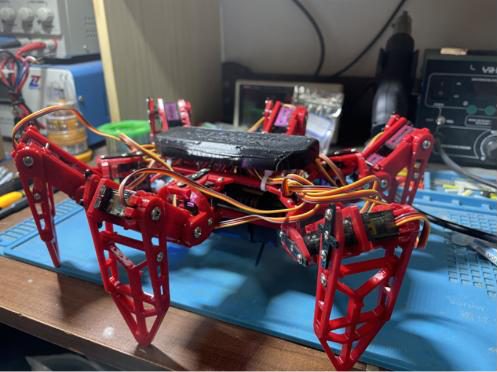
A multi-terrain six-legged robot for education, research and creative projects. It runs on an STM32 with 18 high-torque servos and can walk, turn, crab-walk, dance and run 24 preset actions. A dedicated Android app and a wireless remote control it.
Tech stack
- Main controller
- STM32F407 (STM32F4 series)
- Actuators
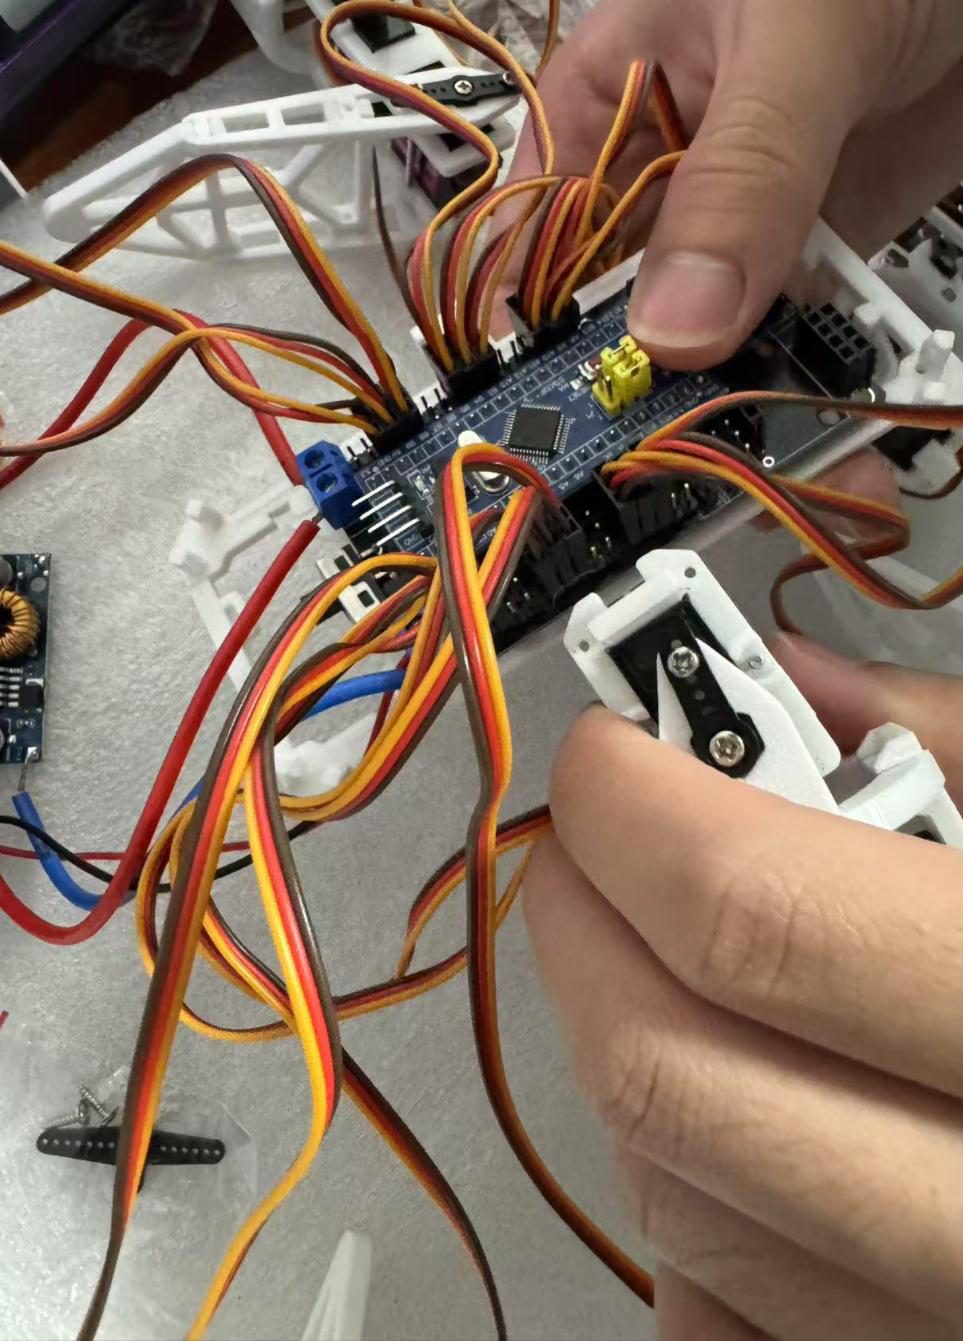
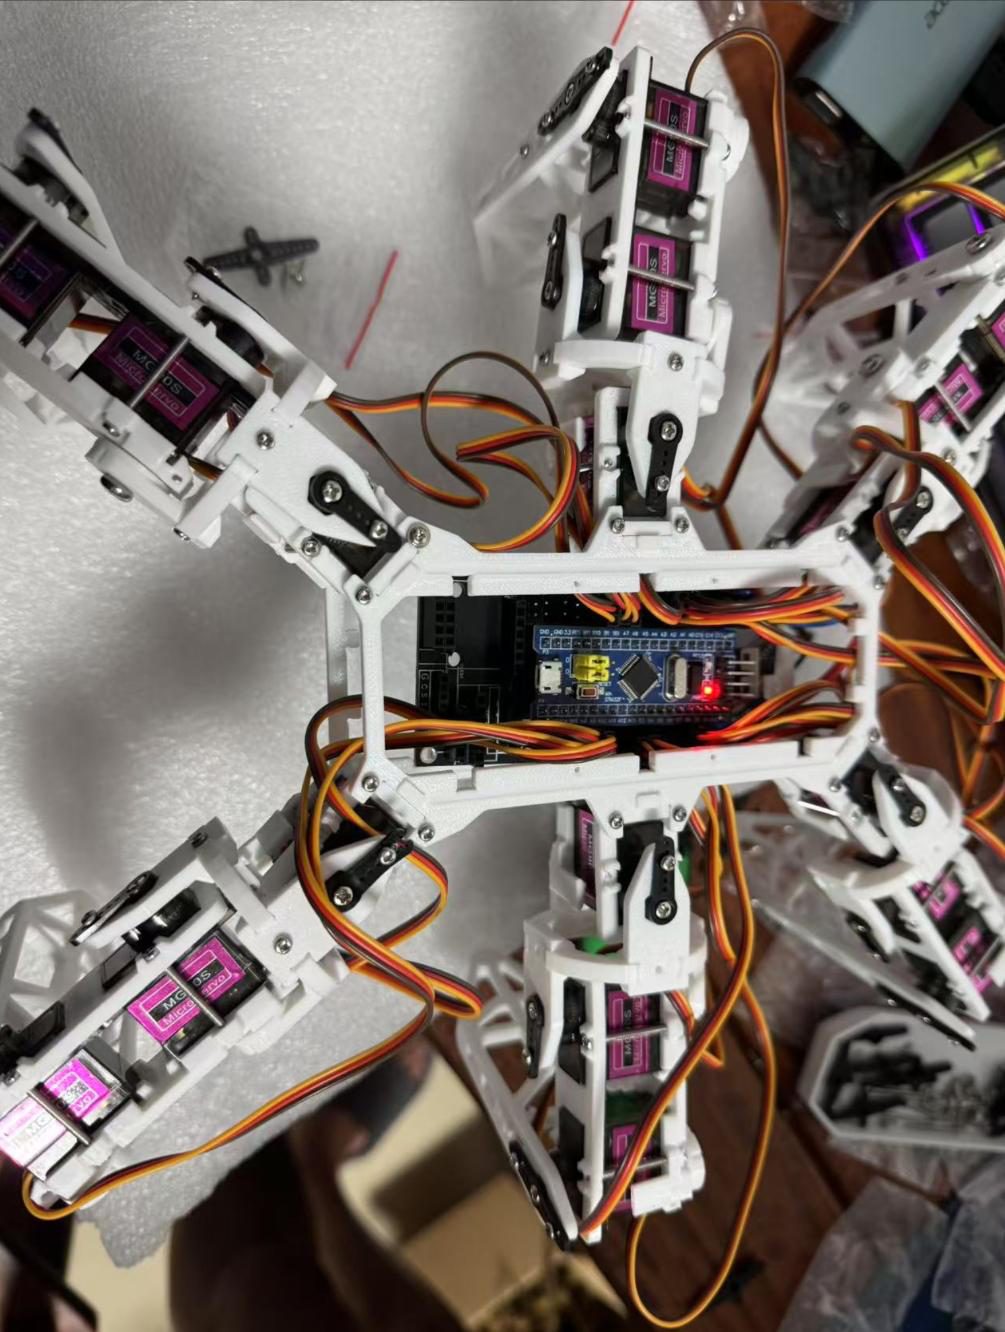
- 18 high-torque metal servos; 24 servo channels on the board
- Sensors
- MPU6050 IMU; optional radar / camera
- Control
- Bluetooth Android app and wireless remote
- Power
- 3S Li-ion battery (11.1 V) with voltage monitoring
- Firmware
- Inverse kinematics, multi-gait algorithms with PID control, IMU attitude estimation, 24 preset actions
- Structure
- 3D-printed modular frame
What we built
- Mechanical design of the six-leg, 18-DOF frame
- PCB design with 24 servo interfaces
- Wireless control and battery voltage monitoring
- Embedded software: gait control, sensor processing, 24 preset actions
- Android app for remote control, mode switching, action selection and parameter tuning
Development time
20 days
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730