
Tracked gel blaster robot
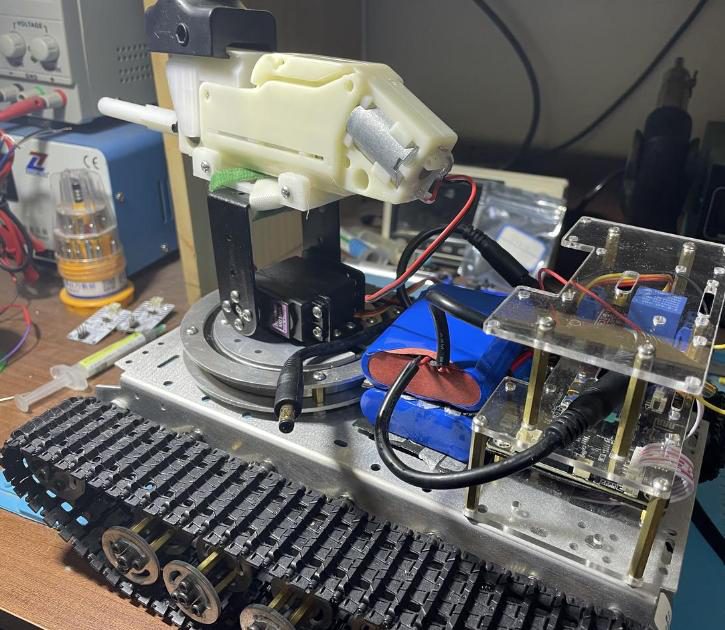
An STM32-based tracked robot that combines a tracked chassis, a gel-bead launcher and an embedded control system. A two-axis servo turret handles aiming and a motor-driven module feeds the launcher. It was built for engineering demos, control experiments and prototype validation.
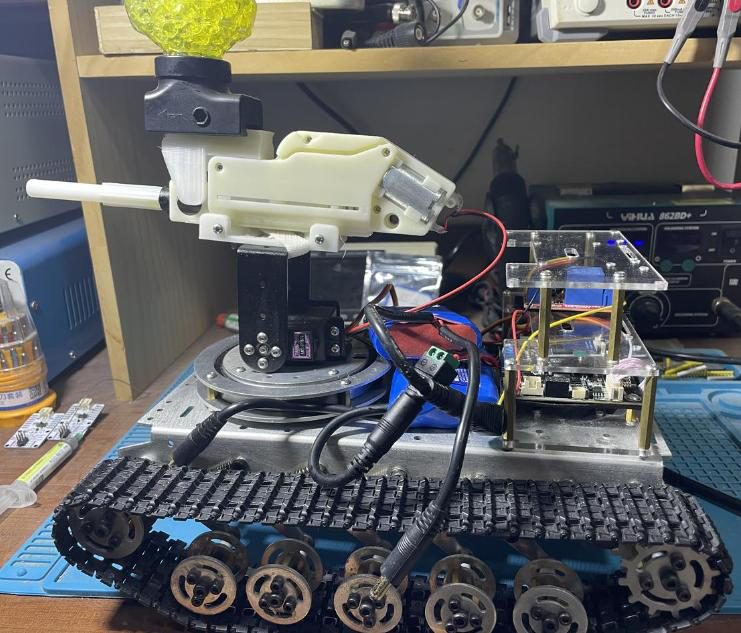
Tech stack
- Main controller
- STM32 series
- Drive
- Tracked chassis, dual DC motors, differential steering
- Turret
- 2-axis servo system
- Launcher
- Motor-driven gel-bead feeding module
- Wireless
- 2.4 GHz remote, serial command expansion
- Power
- Dual supply for motors, launcher and control electronics
- Firmware
- STM32 program for motor, servo and launcher control plus remote/serial communication; expandable to app or PC control
What we built
- Mechanical design: chassis design and machining, rotating turret structure
- Circuit design
- Embedded device code for drive, turret aiming and launcher feed
- Tracked drive system and launcher drive integration
Development time
15 days
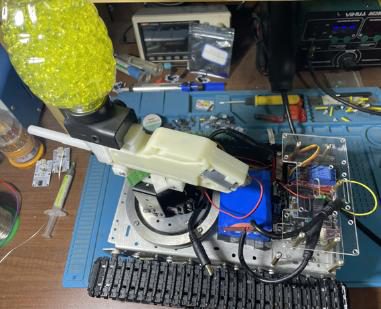
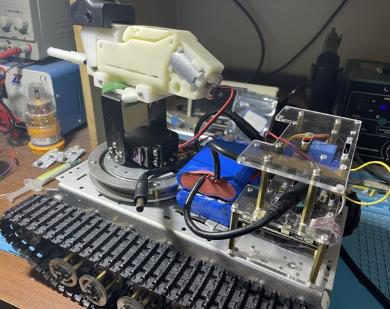
Photos and design files
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730