
Flat-Frame Underwater ROV
A lightweight flat-frame underwater robot for inspection, research, rescue and demo use. A PETG frame holds a clear acrylic electronics chamber, multiple thrusters for omnidirectional movement and a single-axis waterproof gripper for simple grabbing and sampling. An operator drives it from a ground-station app with live video.
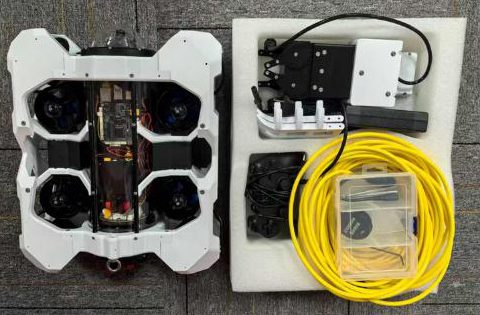
Tech stack
- Main controller
- RK3566 running Linux
- Motion control
- Custom motion-control board with PWM thruster drive, current monitoring and protection
- Sensors
- MS5837 depth/pressure sensor
- Camera
- 1080p / 30 fps underwater camera with live video and recording
- Structure
- PETG frame, transparent acrylic pressure chamber, approx. 400 × 325 × 170 mm
- Performance
- Max operating depth 50 m, endurance up to 3 hours
- Ground station
- Qt-based software for Windows and Linux; UDP command and telemetry; 4G remote control and video
What we built
- Mechanical design and assembly engineering
- Hardware and PCB design
- Embedded device-side software (manual and assisted cruise modes)
- Remote-control terminal and UI
- Machining, integration and system bring-up
Development time
2 months
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730