
F450 quadcopter platform
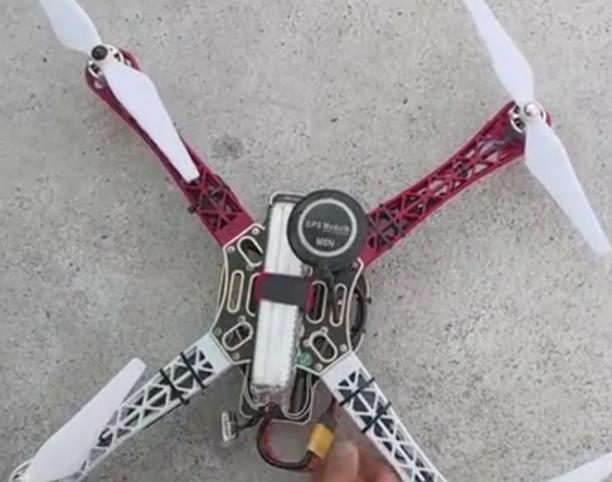
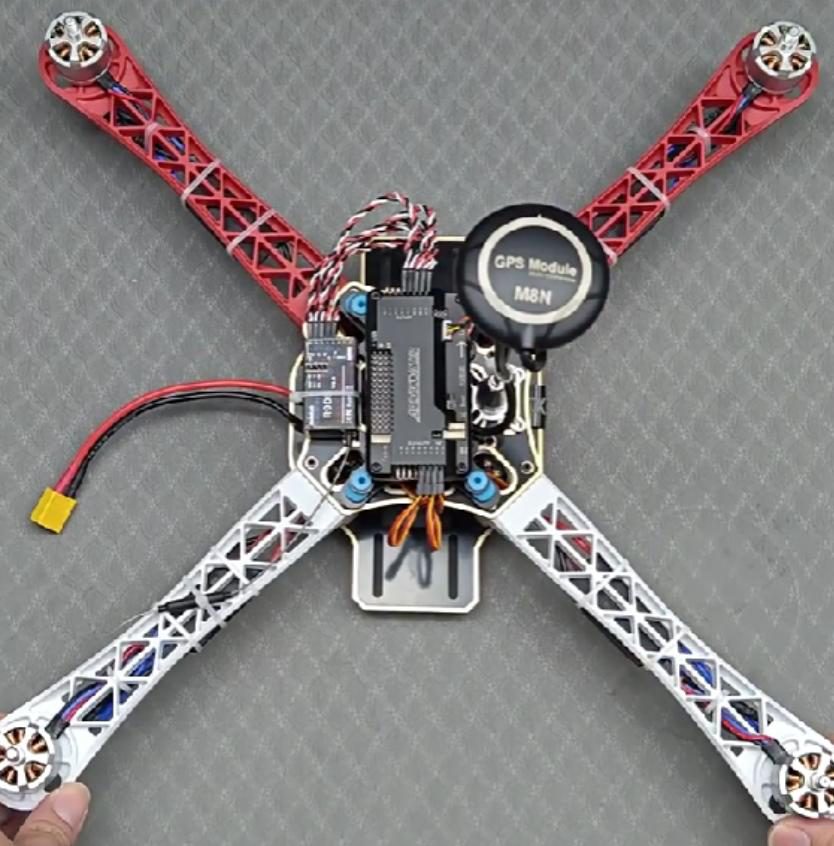
A teaching and research quadcopter built on the F450 frame and the open-source APM flight controller. The team integrates the frame, flight controller, GPS, motors and power system, then assembles, tests and tunes it into a stable, extensible platform for education, prototype development and algorithm validation. Optional work adds autonomous flight such as waypoint navigation, position hold and automatic takeoff and landing.
Tech stack
- Frame
- F450 glass-fibre nylon frame
- Flight controller
- APM (open source)
- GPS
- u-blox NEO-M8N module
- Propulsion
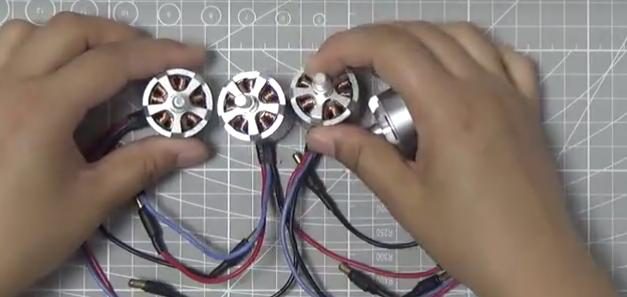
- Brushless motors, ESCs, propellers
- Power
- LiPo battery
- Radio
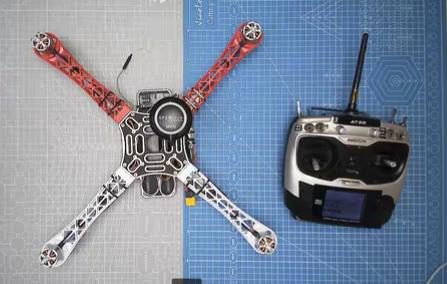
- FlySky / Radiolink remote control
- Ground station
- Mission Planner
What we built
- F450 frame integration and optimization
- Flight controller setup, power distribution, wiring and power system
- Motor, ESC, propeller, GPS and receiver integration
- 3D-printed mounting parts where needed
- Full assembly, flight testing and parameter tuning
- Optional: autonomous waypoint flight, position hold, auto takeoff and landing, path planning and ground-station integration
Photos and design files
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730