
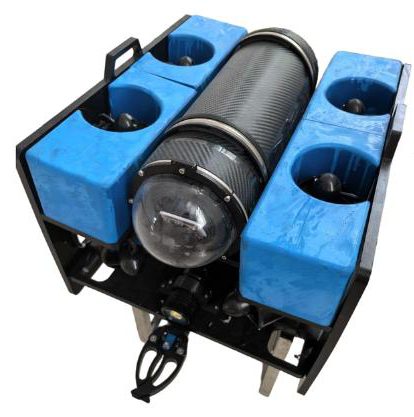
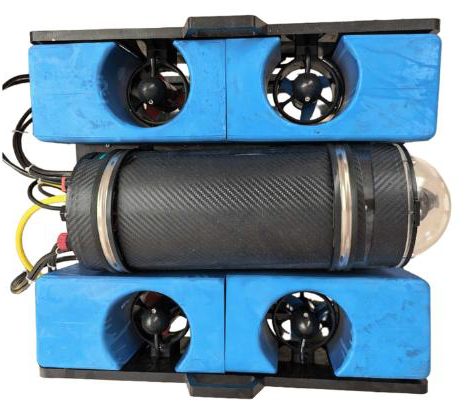
Eight-thruster underwater ROV with arm
A remote-operated underwater vehicle for inspection, object handling, scientific research and environmental monitoring. Eight thrusters give it full six-axis control, and a multi-joint arm at the front grasps and samples. The modular design accepts sonar, water samplers and other tools.
Tech stack
- Main controller
- STM32 / Pixhawk / industrial PC (slide lists all three)
- Propulsion
- 8 thrusters, 8 ESCs; surge, sway, heave, roll, pitch and yaw control
- Manipulator
- 4–6 DOF arm (servo / actuator control)
- Sensors
- IMU and depth sensor; optional sonar, USBL or vision positioning
- Camera
- 1080p camera with high-power LED lighting
- Link
- Tether with surface 4G gateway for real-time video, control and data
- Ground station
- Based on QGroundControl or custom software: live video, recording, sensor display, mission planning and logging
Development time
2 months
Photos and design files
Building something similar?
Review my projectOr email [email protected] · WhatsApp +1 (323) 719-3730